Problem
Ayaz was developed for TEKNOFEST across the 2024–2026 competition seasons. Operating the vehicle required more than sending commands: the shore team needed one place to follow telemetry, mission state, onboard services and perception output while the vehicle was on the water.
Ground control station
The ground control station was designed in Figma and implemented with Qt/QML. My work brought together the map, live vehicle telemetry, operating modes, manual waypoints, mission stages and the status of onboard services. MAVLink and MAVROS provide the communication layer between the operator tools and the vehicle.
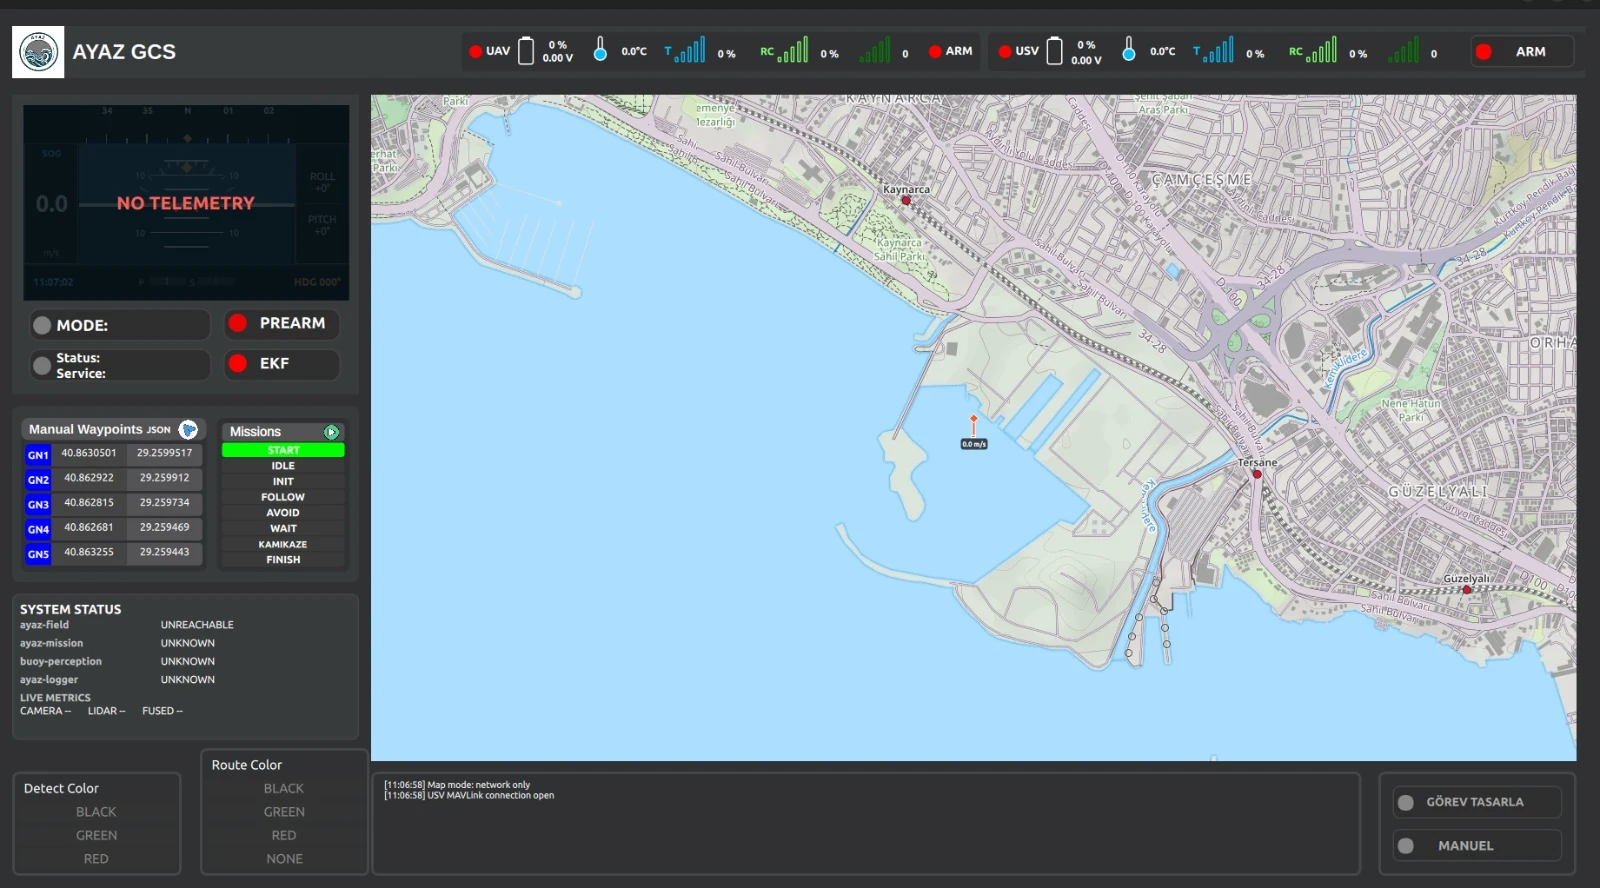
The ground control station keeps vehicle state, mission control and service health visible in one operator view.
Perception and mapping
My vehicle-side work also covered image processing, sensor fusion, LiDAR filtering and local mapping. The local map combines the vehicle pose with detected course objects so the perception result can be inspected as part of the mission rather than as isolated sensor output.
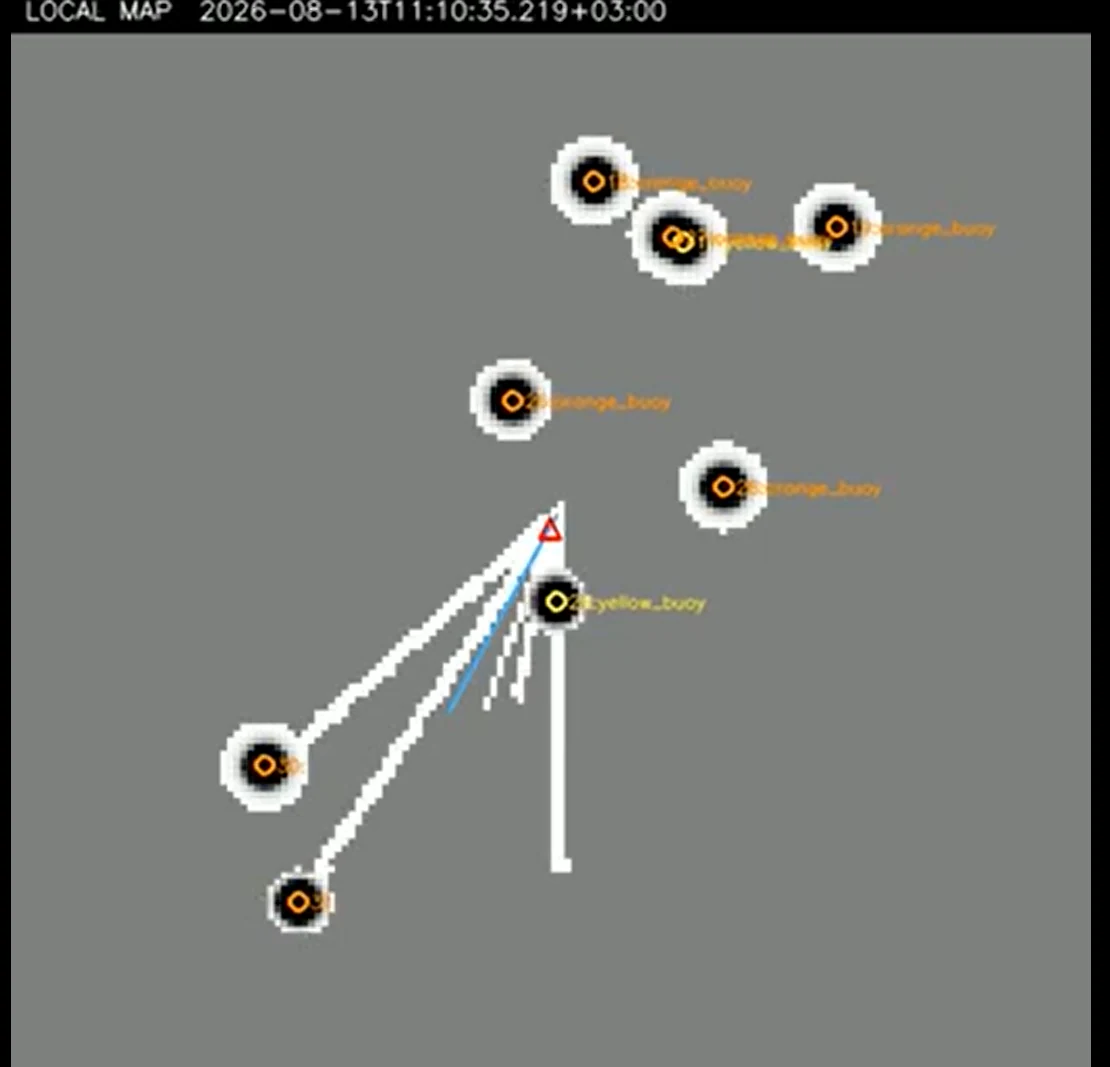
A local map produced from the perception pipeline during development.
Field testing
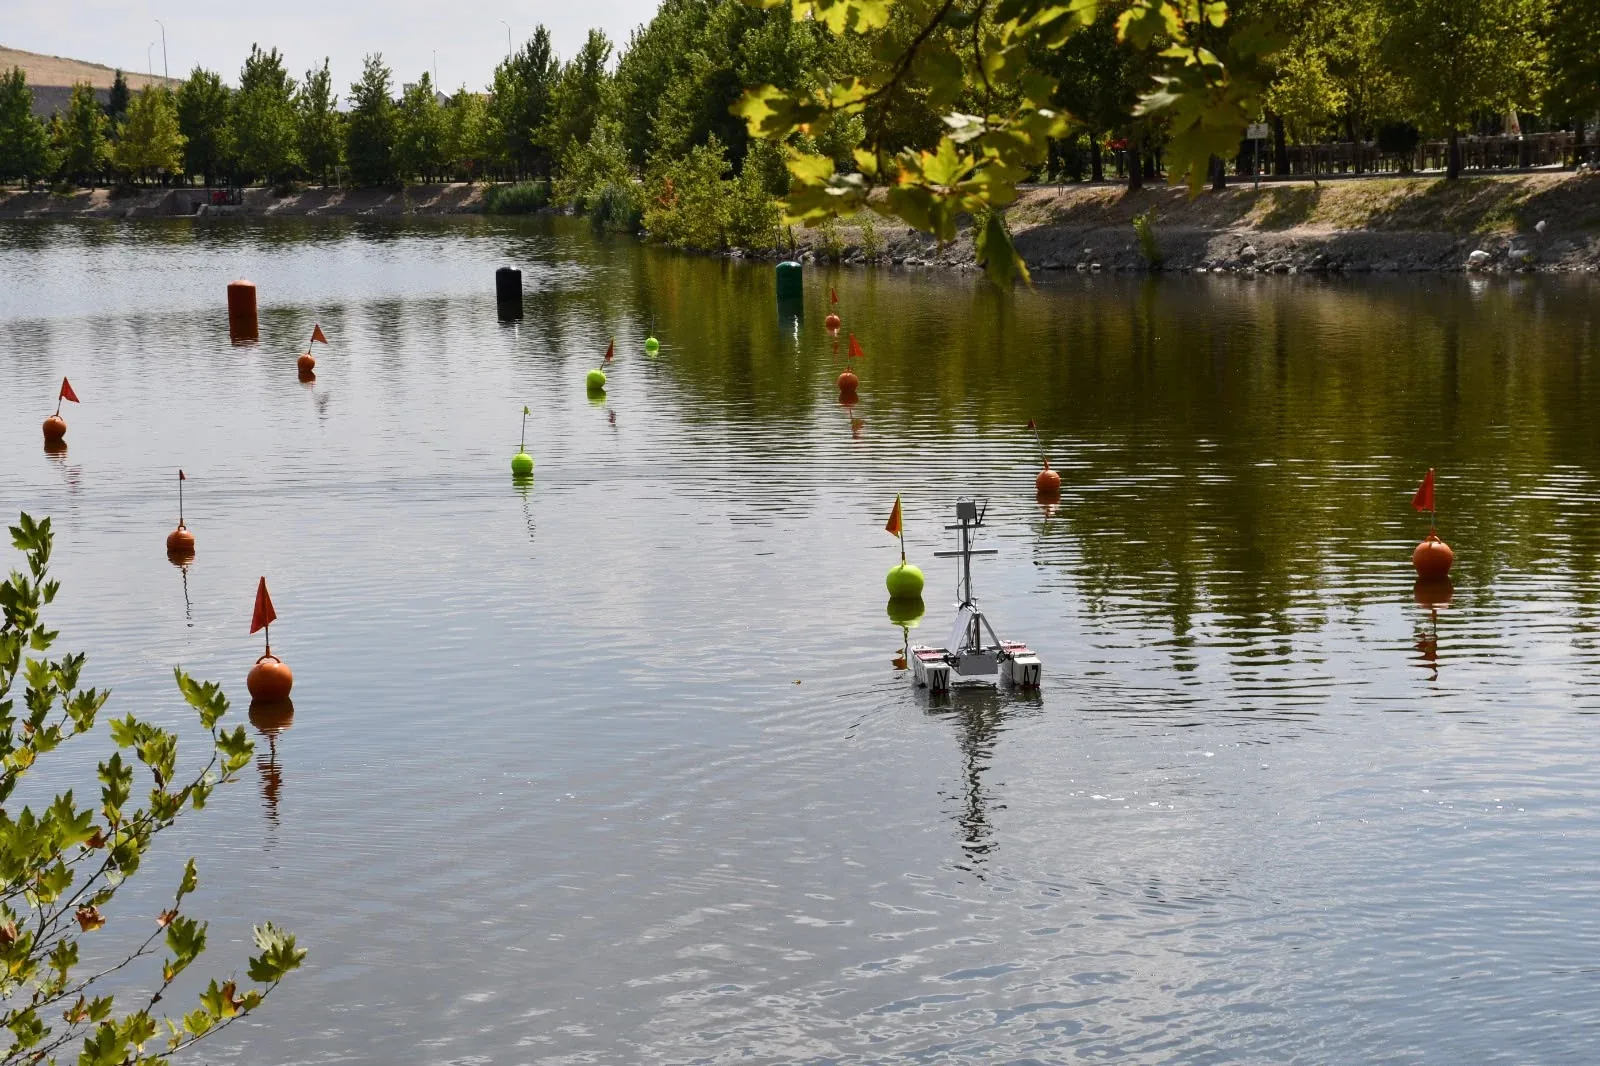
The integrated system was exercised during lake tests with the vehicle moving through a buoy-marked course. These sessions connected the software to the conditions it was built for: real telemetry, onboard service state, sensor output and operator supervision at the same time.
Result
The project produced an operator-facing workflow that brought telemetry, mission controls, service health and perception output into one interface, alongside the onboard image-processing, sensor-fusion and mapping pipeline.
Recognition
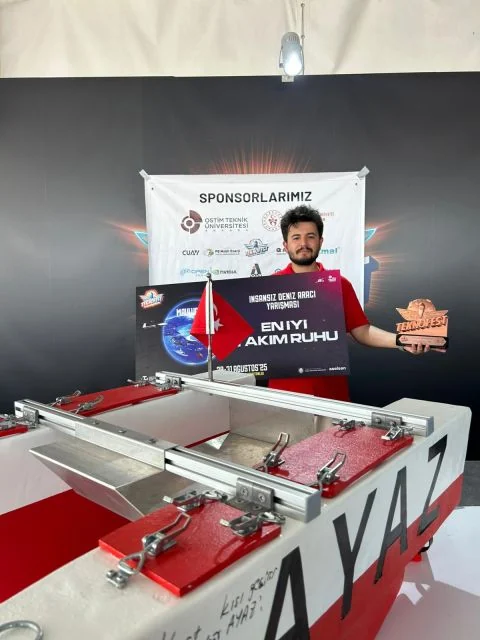
Ayaz received the Best Team Spirit Award at TEKNOFEST in 2025.