About
I build backend, perception and control software for autonomous and defense systems. My recent work includes a C++20/gRPC radar track-correlation service at HAVELSAN, a modular ROS 2 autonomous-driving stack in Gazebo, and vehicle and ground-control software for TEKNOFEST unmanned surface vehicles.
I am most interested in systems that must make reliable decisions from noisy sensor data under timing and safety constraints. I prefer measurable engineering: deriving thresholds from the system’s physics, keeping core logic independently testable, and documenting why an approach failed as carefully as why the final one worked.
I completed my B.Sc. in Software Engineering at Kocaeli University with a 3.56/4.00 GPA.
Projects 13
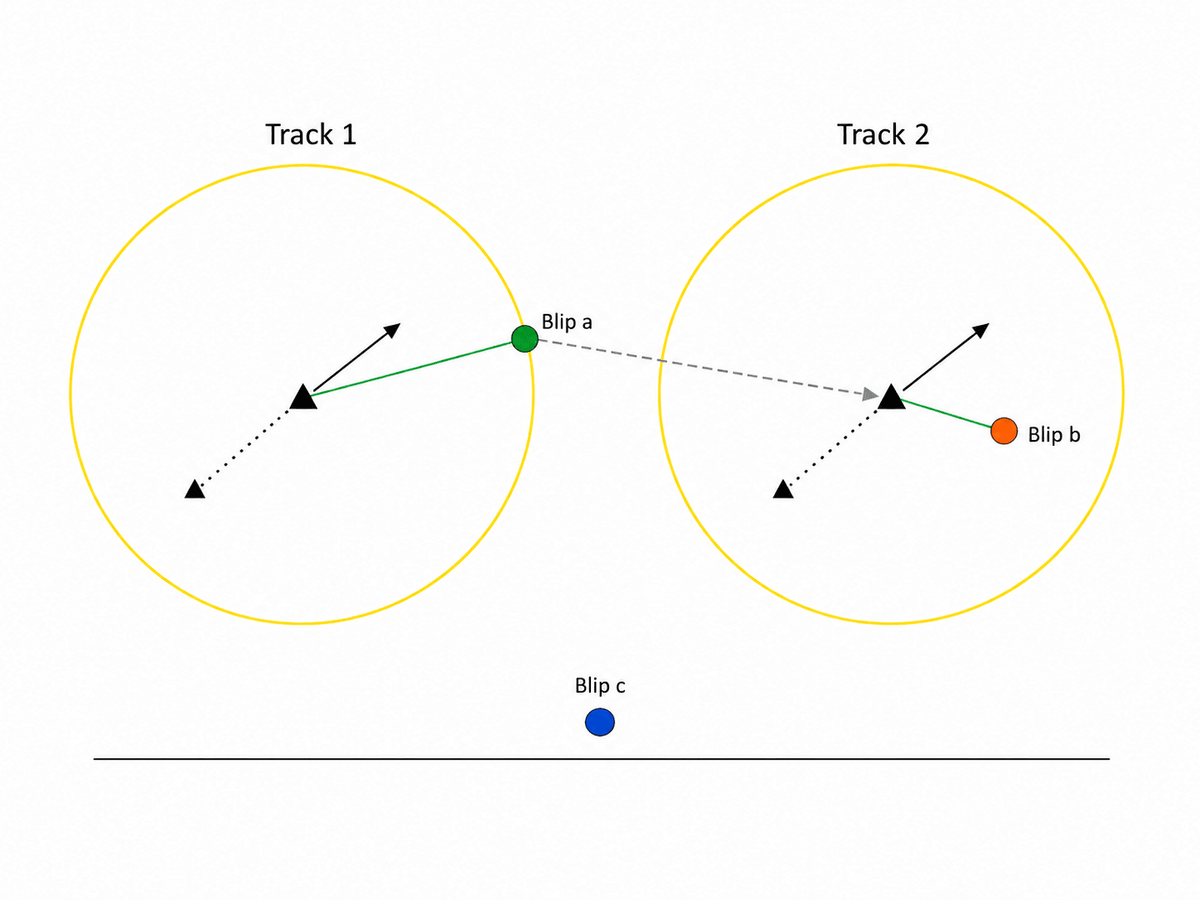 Radar track correlation backend
A C++20 gRPC service that turns raw radar blips into a correlated tactical picture for an AEW&C display.
C++20 · gRPC · Protocol Buffers · GoogleTest · spdlog · CMake
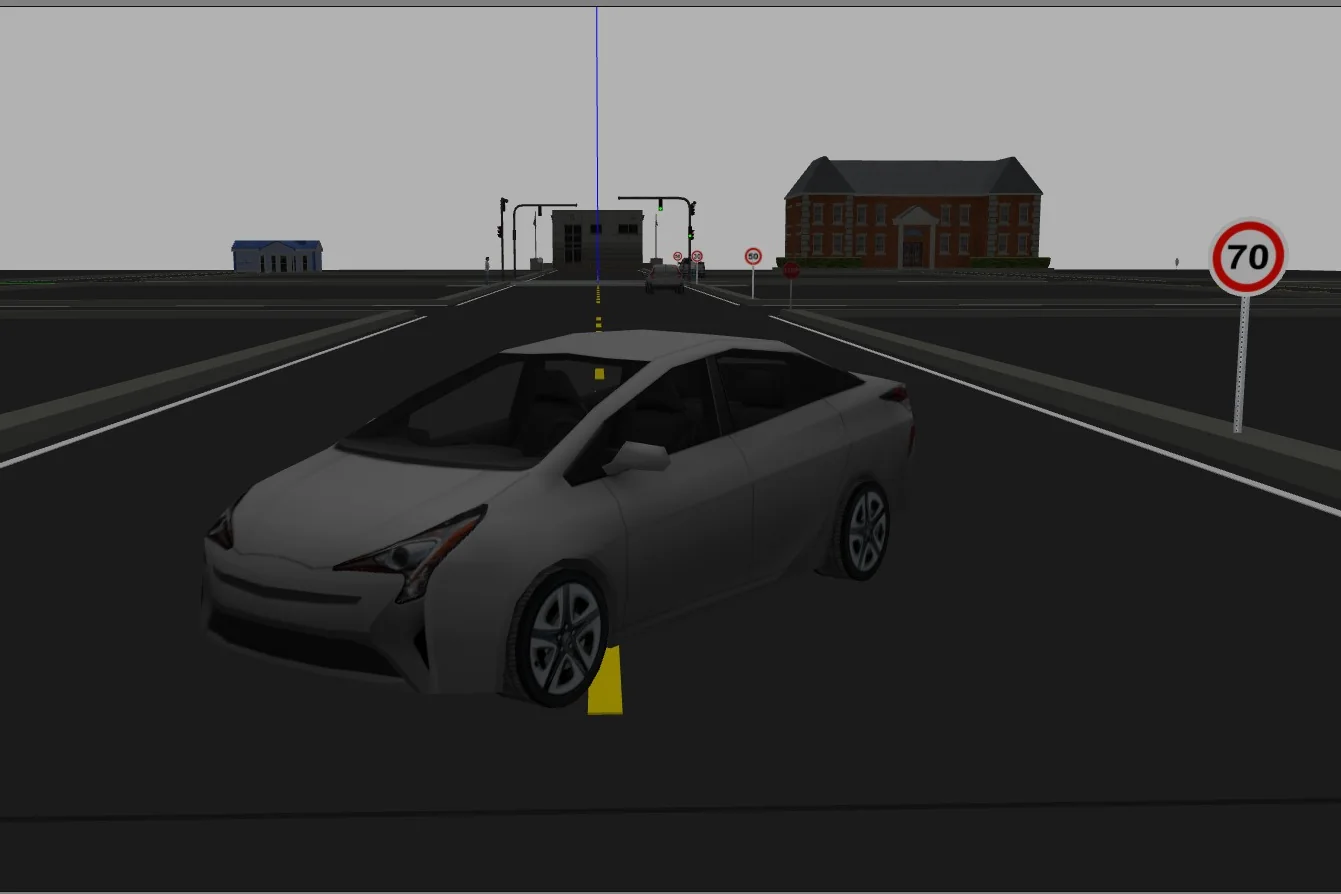 Layered autonomous driving in Gazebo
A ROS 2 driving stack integrating lane keeping, YOLO perception, LiDAR safety, SLAM and Nav2 in simulation.
ROS 2 · Gazebo · Python · C++ · YOLO11 · Nav2 · OpenCV
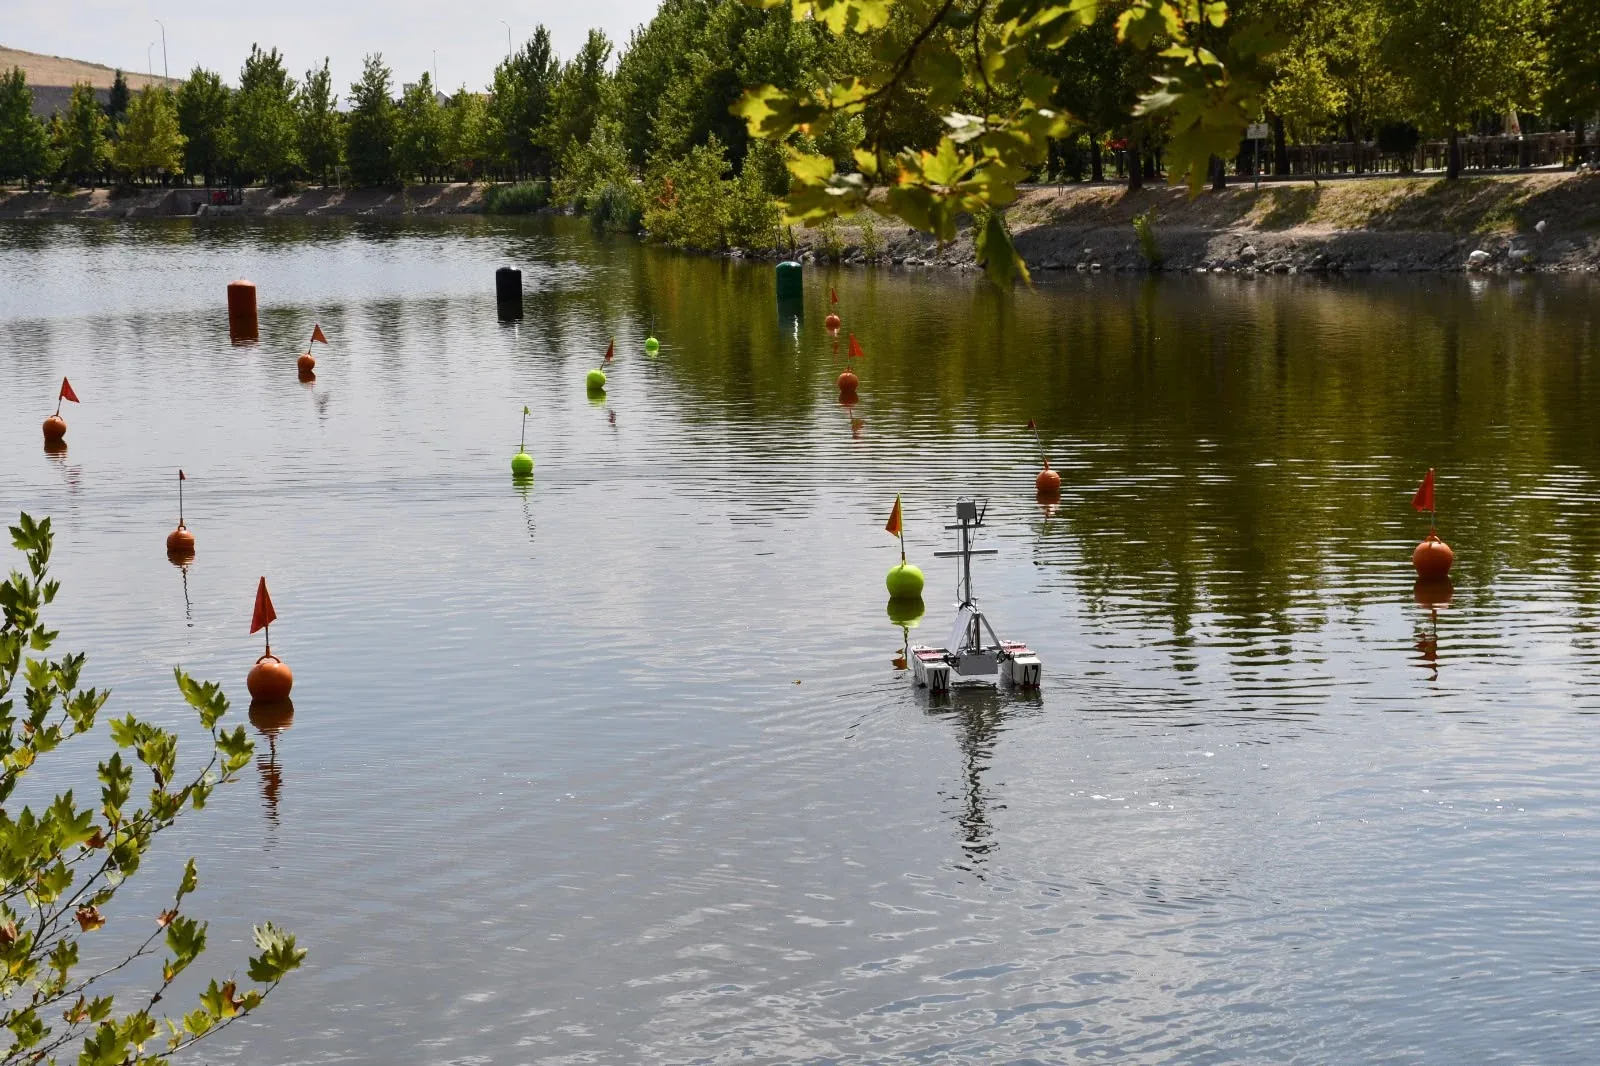 Ayaz autonomous surface vehicle
Ground control, telemetry and perception software for an autonomous surface vehicle tested on water.
Python · MAVROS · Qt/QML · OpenCV
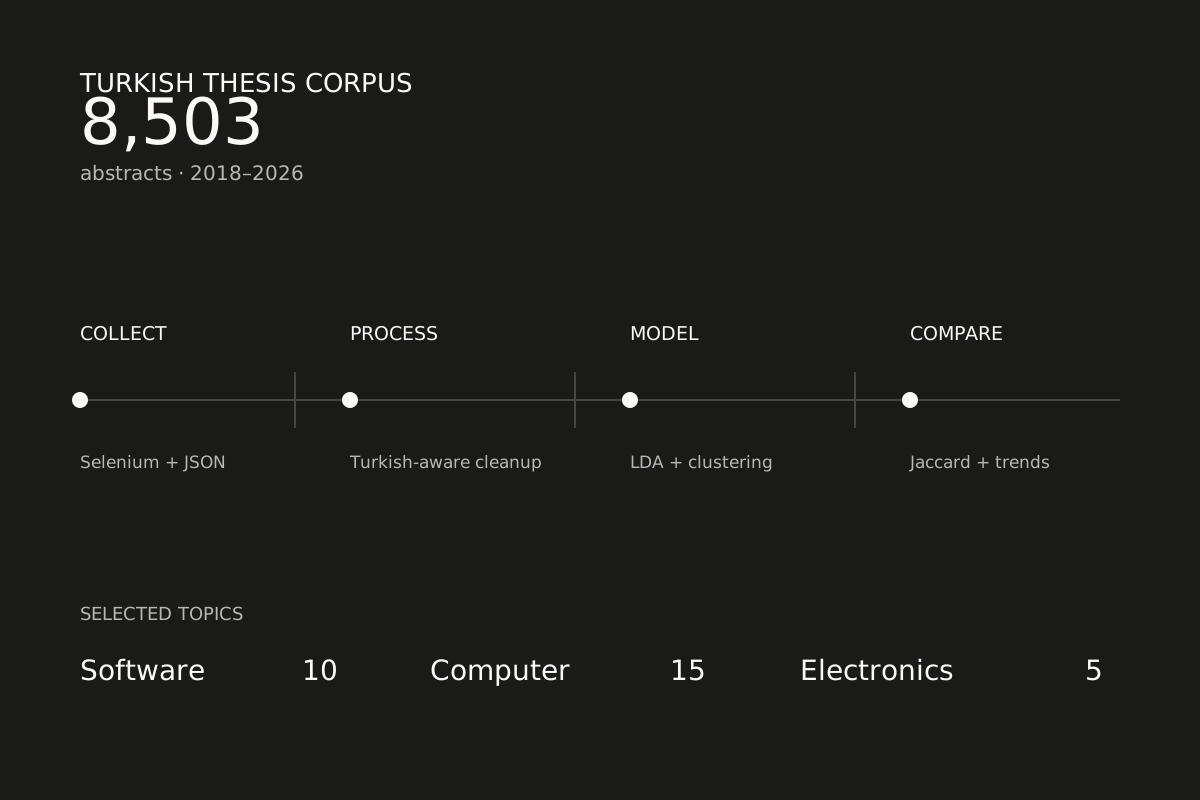 Topic discovery across Turkish theses
An NLP pipeline that modeled 8,503 Turkish thesis abstracts to compare research themes across three engineering disciplines.
Python · Selenium · Gensim · scikit-learn · LDA · K-Means
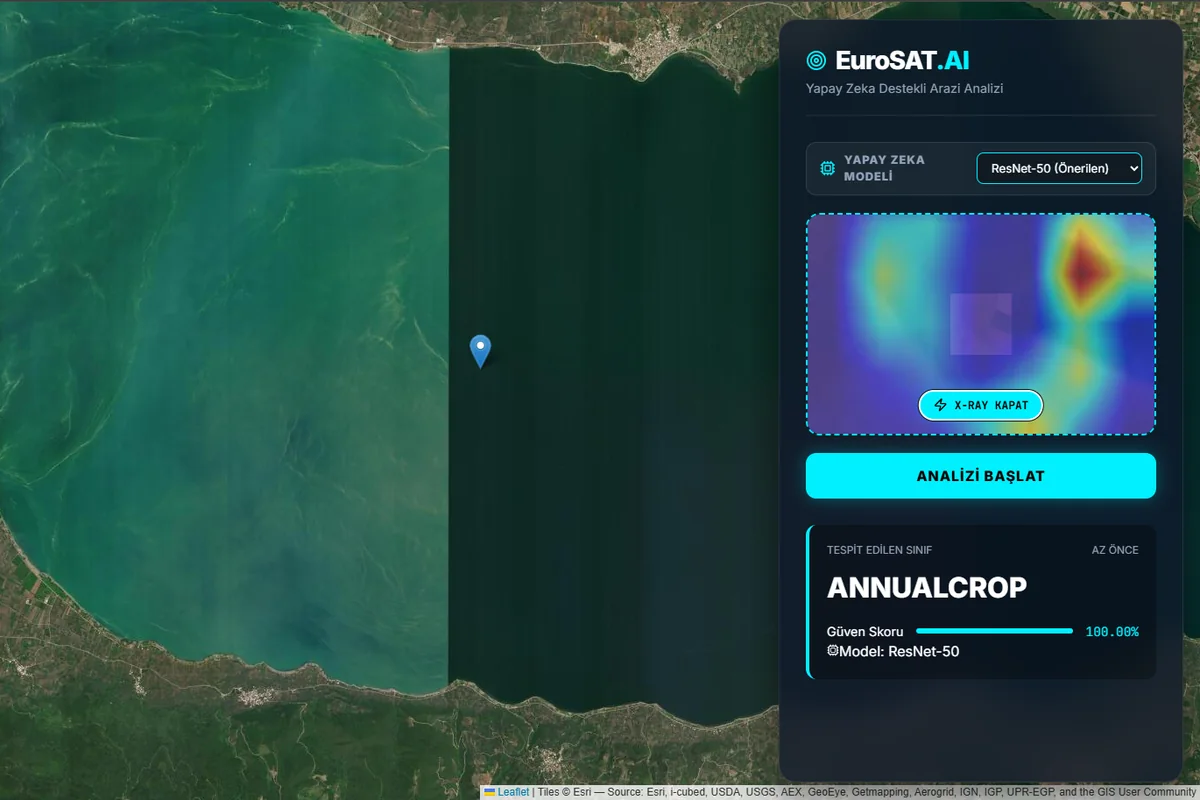 Explainable satellite land classification
A FastAPI and React application comparing CNN models on EuroSAT and exposing Grad-CAM explanations through an interactive map.
Python · PyTorch · FastAPI · React · Grad-CAM · Leaflet
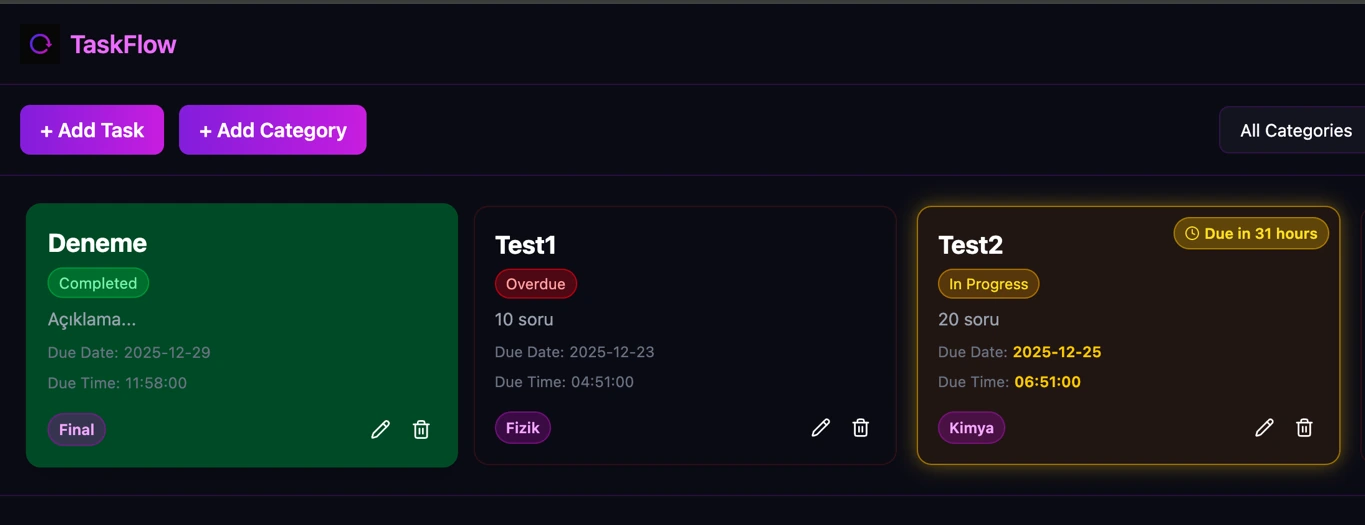 TaskFlow — task and file management
A React and FastAPI application with task planning, categories, file attachments, admin operations and statistics.
Python · FastAPI · React · SQLAlchemy · SQLite · JWT · Pytest
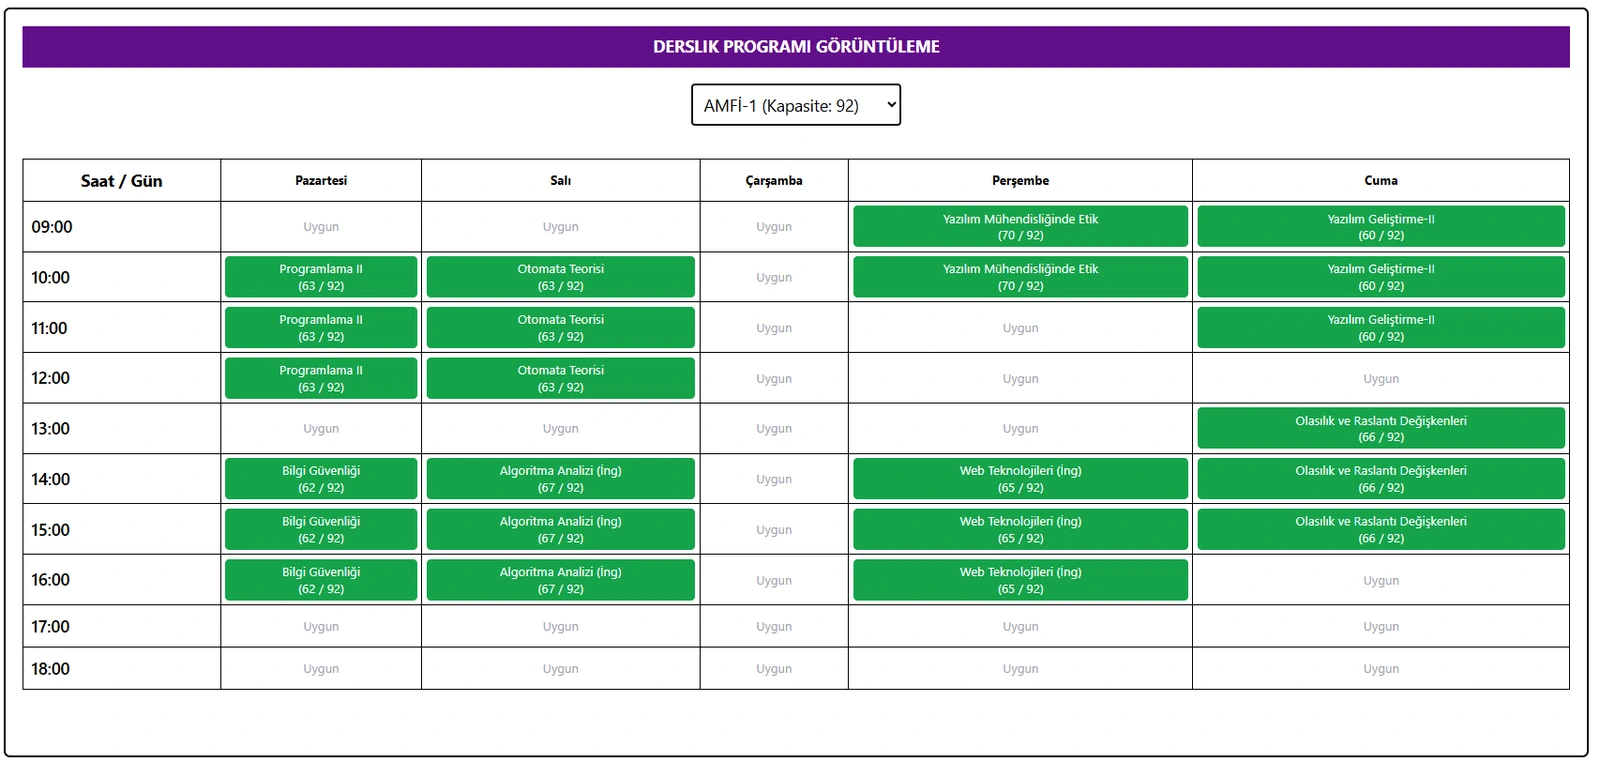 University department management
React and FastAPI software for course and exam scheduling, conflict checks, approvals, randomized seating and PDF exports.
Python · FastAPI · React · SQLAlchemy · SQLite · Tailwind CSS · JWT
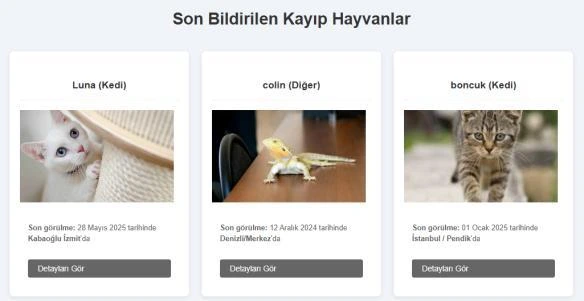 PetFinder — lost-pet reporting platform
A Django application with pet listings, photo-based sighting reports, user accounts, messaging and CSV import/export.
Python · Django · SQLite · HTML · CSS · JavaScript
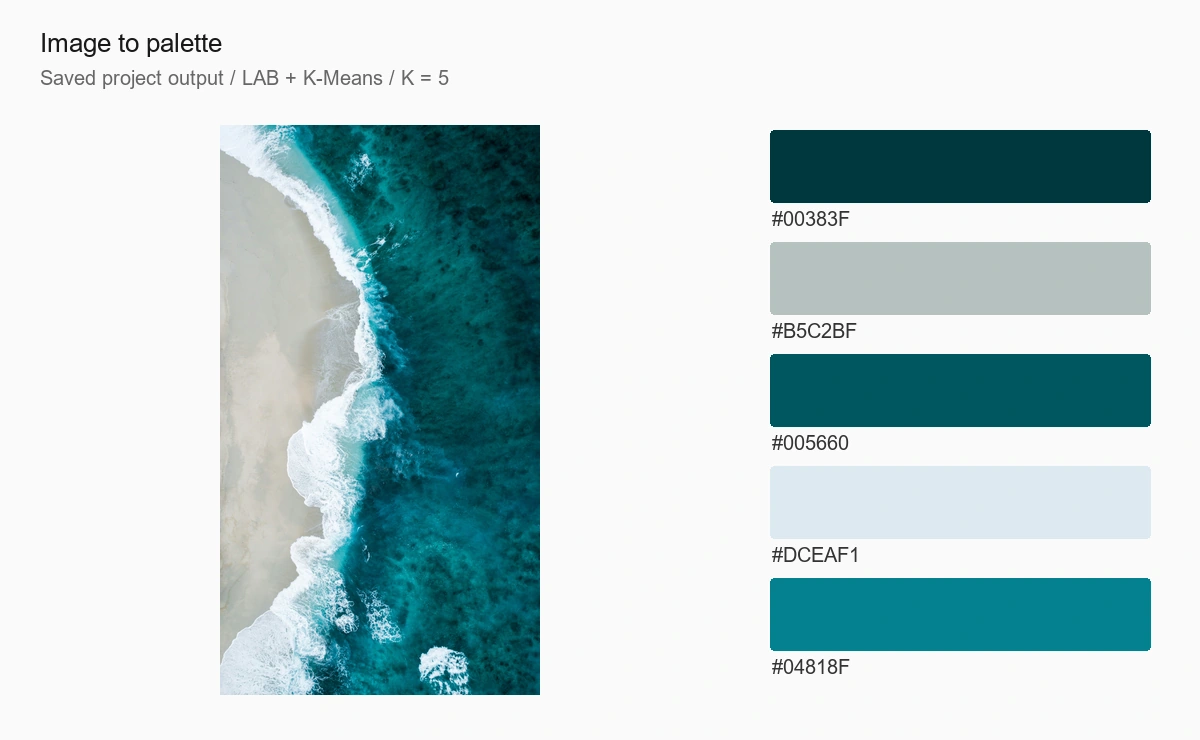 Image-to-color-palette application
Django and OpenCV software for image uploads, LAB-space K-Means clustering, HEX output and a personal palette archive.
Python · Django · OpenCV · scikit-learn · K-Means · JavaScript
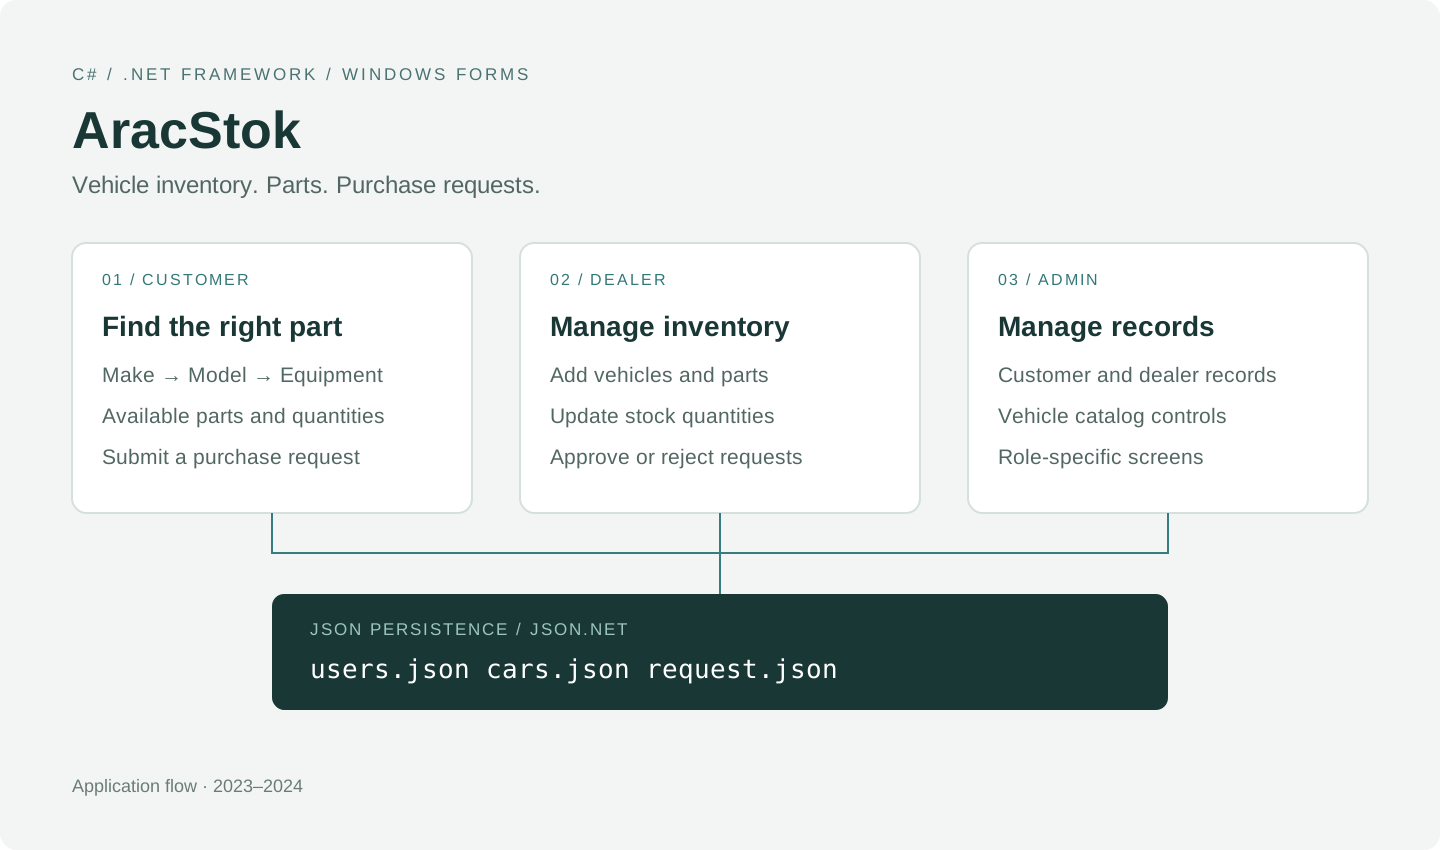 Vehicle and spare-parts inventory in C#
A Windows Forms application for vehicle catalogs, spare-parts stock, customer requests and dealer approval workflows.
C# · .NET Framework · Windows Forms · JSON.NET · LINQ
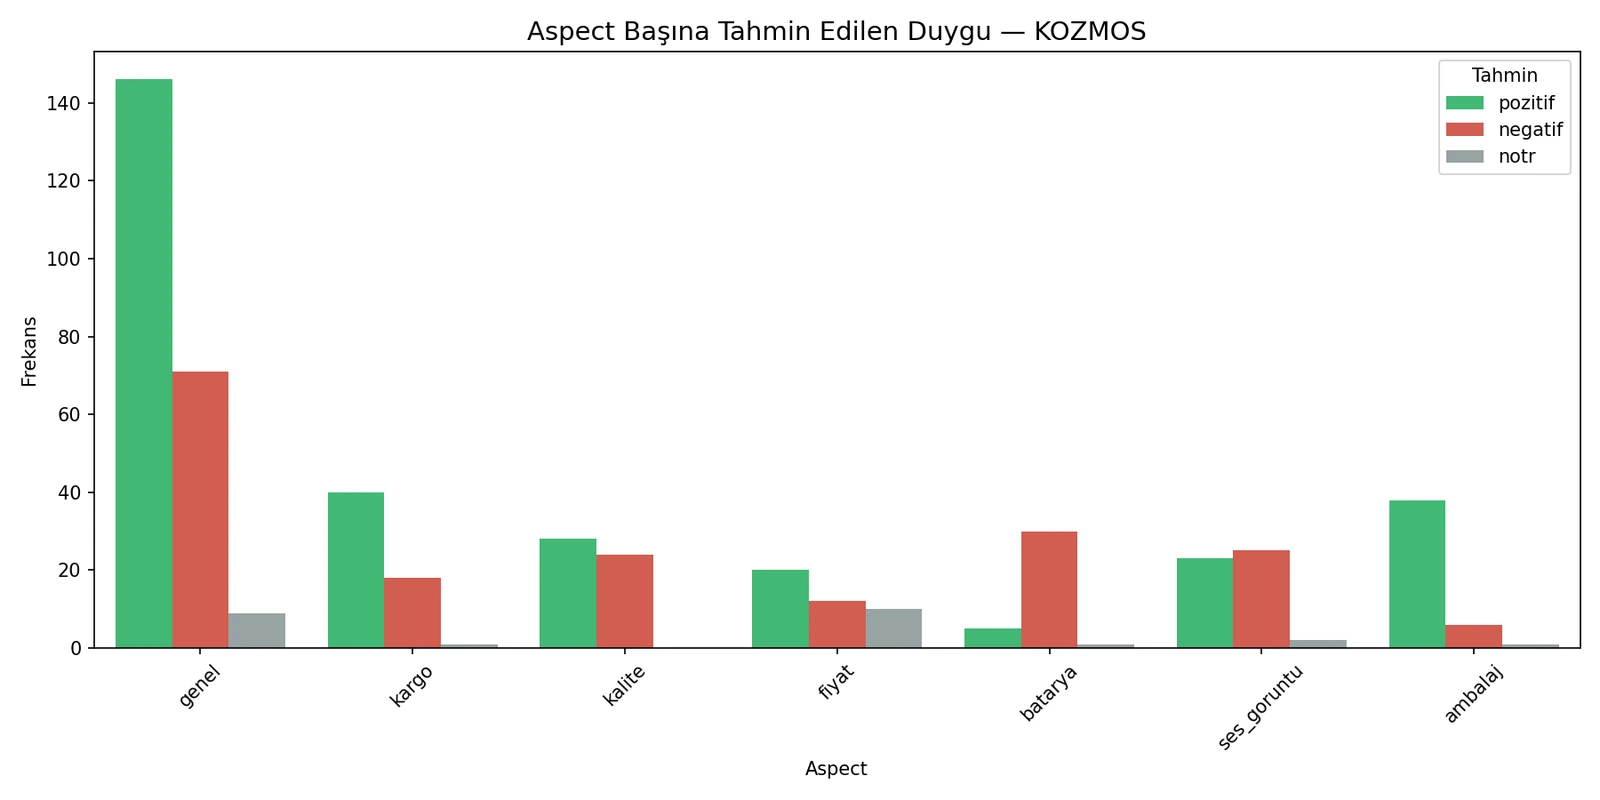 Aspect-based sentiment in Turkish product reviews
An NLP study comparing lexicon, TF-IDF, BERTurk and KOZMOS approaches on 3,358 aspect-sentiment pairs.
Python · Selenium · scikit-learn · PyTorch · Transformers · Captum
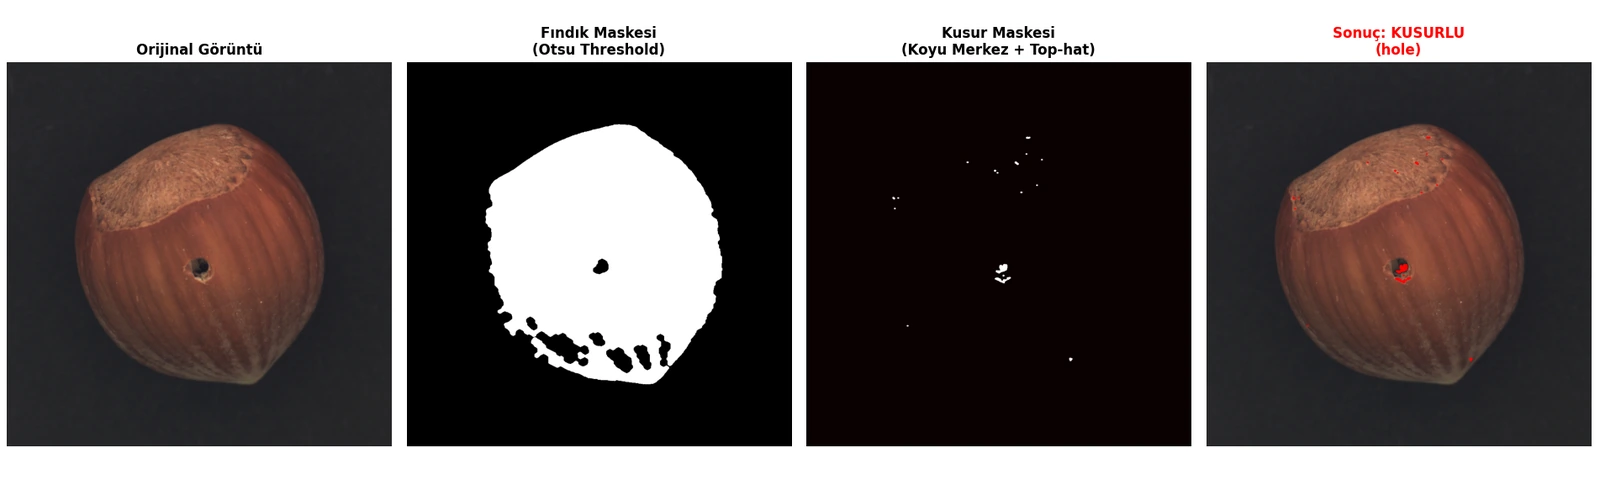 Hazelnut surface-defect segmentation with OpenCV
Otsu, Canny, Top-Hat and morphological pipelines for crack, hole, print and cut defects in MVTec Hazelnut images.
Python · OpenCV · NumPy · scikit-image · Matplotlib
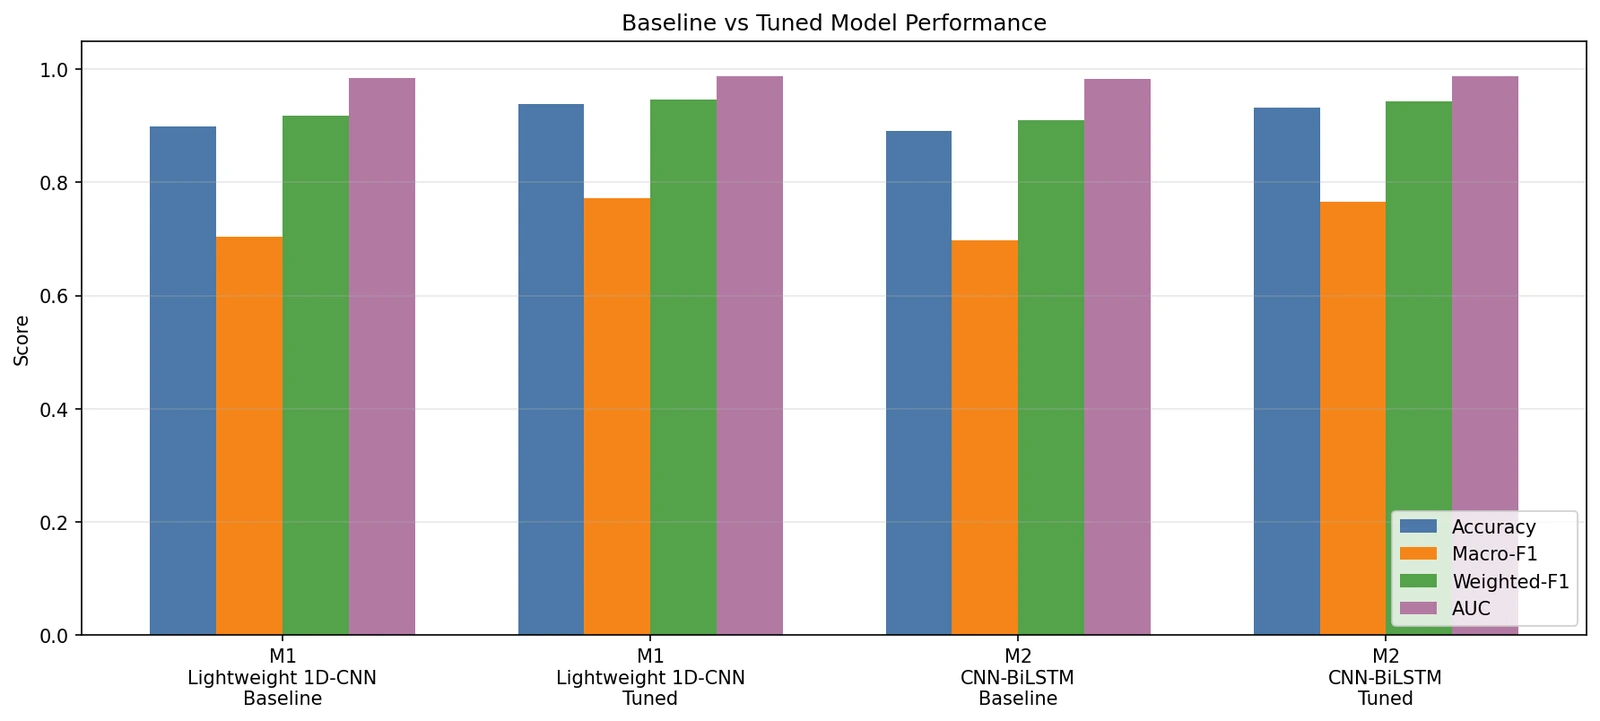 Five deep-learning architectures for ECG classification
A MIT-BIH comparison of CNN, BiLSTM, CBAM, MAB-Net and CAT-Net with imbalance handling and hyperparameter experiments.
Python · PyTorch · CNN · BiLSTM · Attention · Transformer
Experience
- Software Development Intern
HAVELSAN A.Ş.
- Worked on a C++ and gRPC-based MSI backend system, developing radar blip-to-track generation, blip-track correlation and IFF processes. Designed the backend structure using a hexagonal architecture approach.
- Created 108 unit tests using GoogleTest; tested multithreaded service flows and implemented and used spdlog-based logging.
- Volunteer Software Development Intern
INOSENS
- Analyzed the limitations of DBSCAN in a LiDAR-based object tracking system and integrated an Adaptive DBSCAN approach.
- Compared DBSCAN and Adaptive DBSCAN using Python, measured tracking performance and documented the results.
- Software Development Intern
Ecolarium
- Built 10+ API endpoints for a Django-based web application and handled database, backend and RESTful API integration tasks.
- Performed API testing using Postman and improved frontend-backend communication and logging processes.
- Software Developer
Meftun-u Derya · TEKNOFEST Unmanned Surface Vehicle Competition
- Designed PID-based motion control algorithms and optimized speed and heading parameters; implemented state-machine-based decision mechanisms for autonomous task transitions and emergency scenarios.
- Integrated an OpenCV-based vision pipeline with the onboard camera for autonomous object detection.
- Software Developer
Ayaz · TEKNOFEST Unmanned Surface Vehicle Competition
- Integrated MAVLink and MAVROS to establish bidirectional communication between the vehicle and the ground control station.
- Built a PyQt-based ground control station with 4 modules for mission tracking, mapping, sensor visualization and logging.
- Fused LiDAR and camera data for object detection and integrated the perception output into autonomous mission logic.
- Received the 2025 TEKNOFEST Best Team Spirit Award.
Education
- B.Sc. Software Engineering
Kocaeli University · GPA 3.56 / 4.00
Ranked 3rd in the Department